TRON Industry Weekly Report: Technology stocks weaken, BTC falls below $80000, detailed analysis of AI-driven robotics executing infrastructure by Axis Robotics
 Detailed total financing of 1,200 million US dollars, led by Hack VC, with participation from Nomad Capital, Pi Network, and 10K Ventures — building AI-driven intelligent robot execution infrastructure Axis Robotics.
I. Outlook
1. Macroeconomic Summary and Future Forecast
Macroeconomic summary for this week (October 19, 2026 - October 25, 2026): The global market is affected by both energy inflation and concerns over technology stock valuations. On October 23, Brent crude oil closed at $116.72 per barrel, with the S&P 500 and Nasdaq falling by 0.5% and 0.7% respectively for the week; safe-haven buying pushed the yield on the 10-year U.S. Treasury down by about 11 basis points to 4.987%, reflecting the coexistence of inflation risks and growth concerns.
Macroeconomic forecast for next week (October 26, 2026 - November 1, 2026): Increased market volatility is expected, focusing on the Federal Reserve's decision, U.S. GDP, and PCE, as well as earnings reports from large technology companies. The Federal Reserve's interest rate decision will be announced at 00:00 on October 29, Beijing time, with mainstream market expectations for rates to remain unchanged; at 20:30 on the same day, Q3 GDP and September PCE will be released. If the Federal Reserve signals continued rate hikes and core inflation remains strong, stock market valuations may continue to be under pressure; if the policy language is dovish and inflation cools, it will be beneficial for sentiment recovery. High oil prices mean that even if the rate hike is paused this time, it cannot be directly interpreted as the end of tightening.
2. Cryptocurrency Market Changes and Warnings
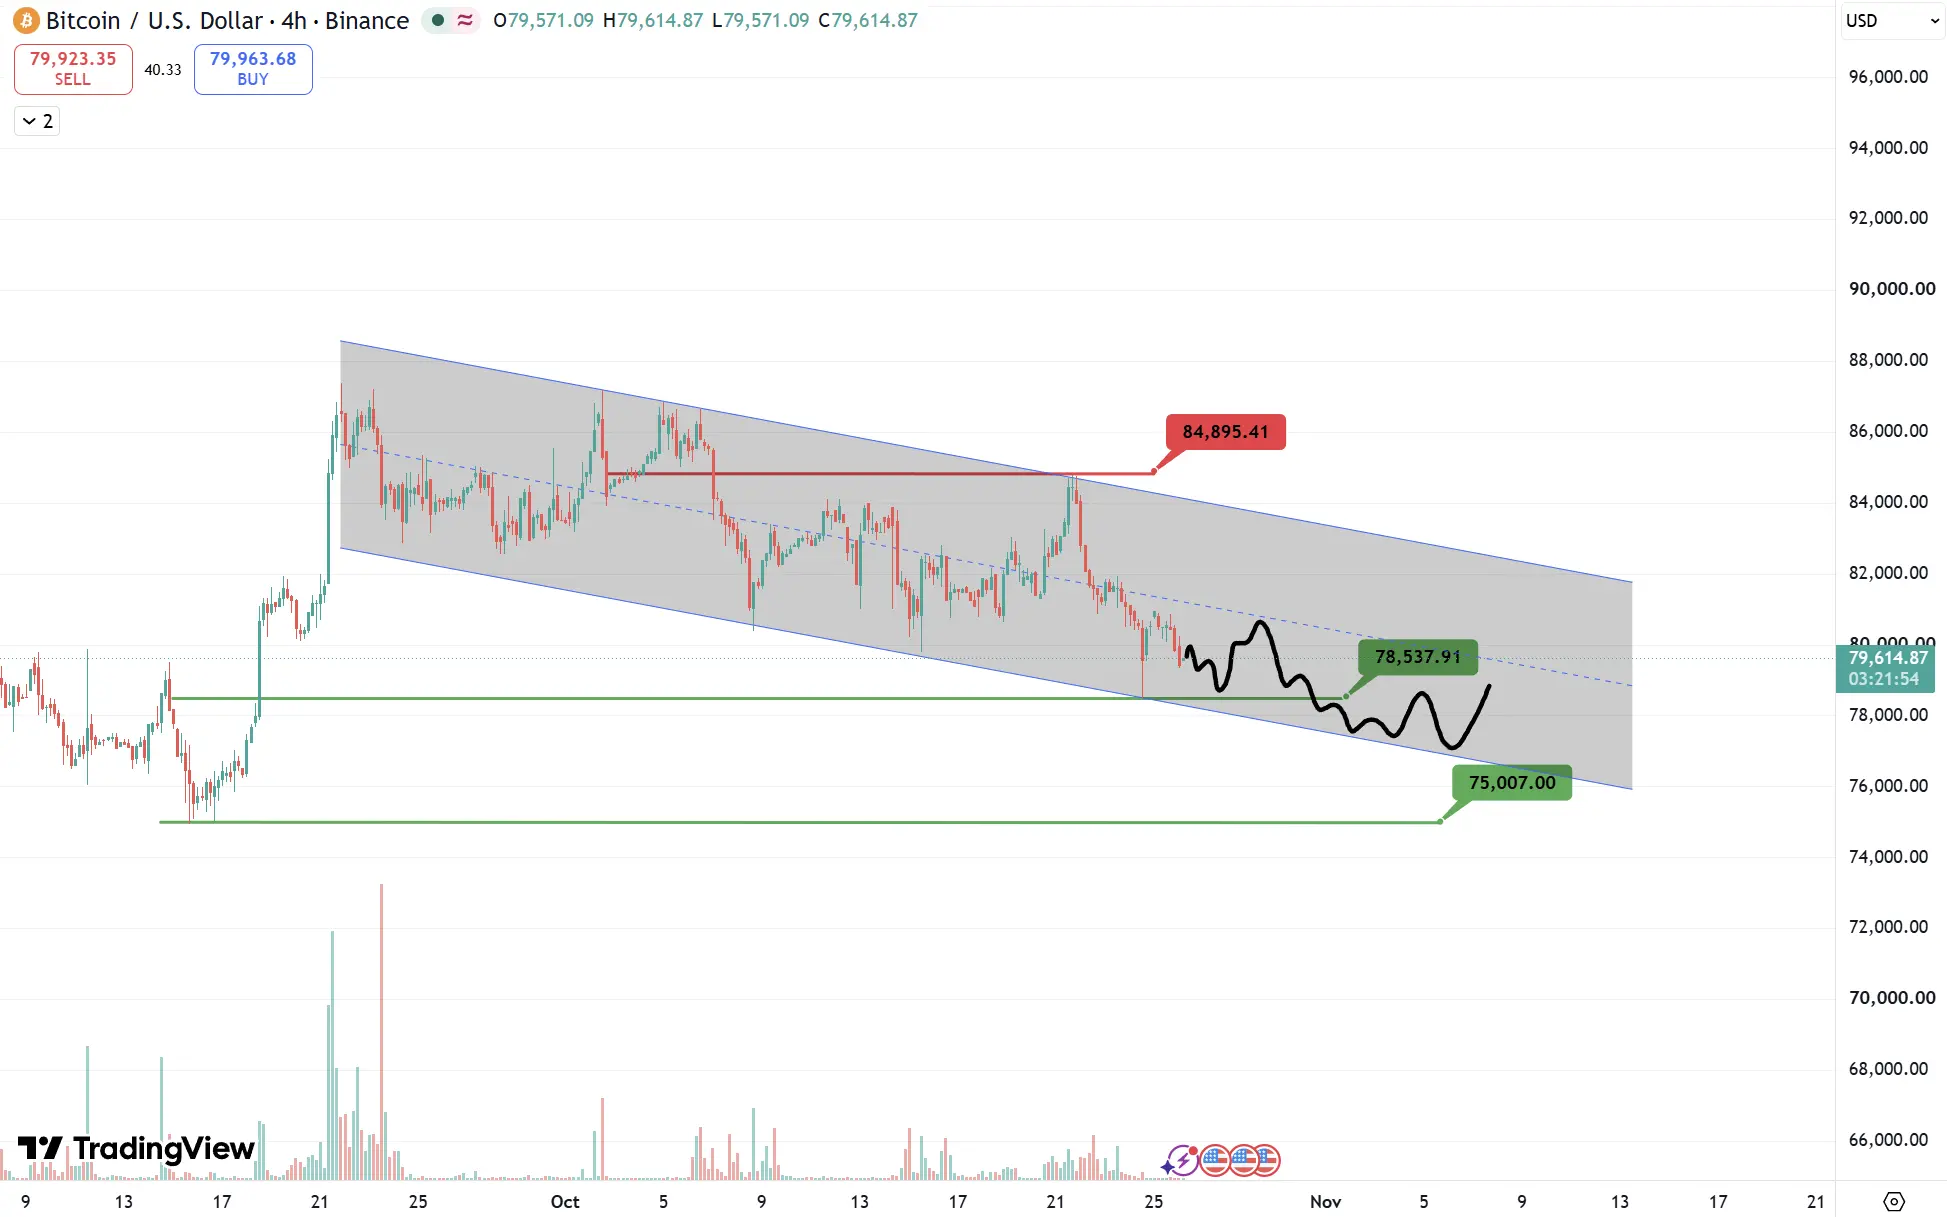
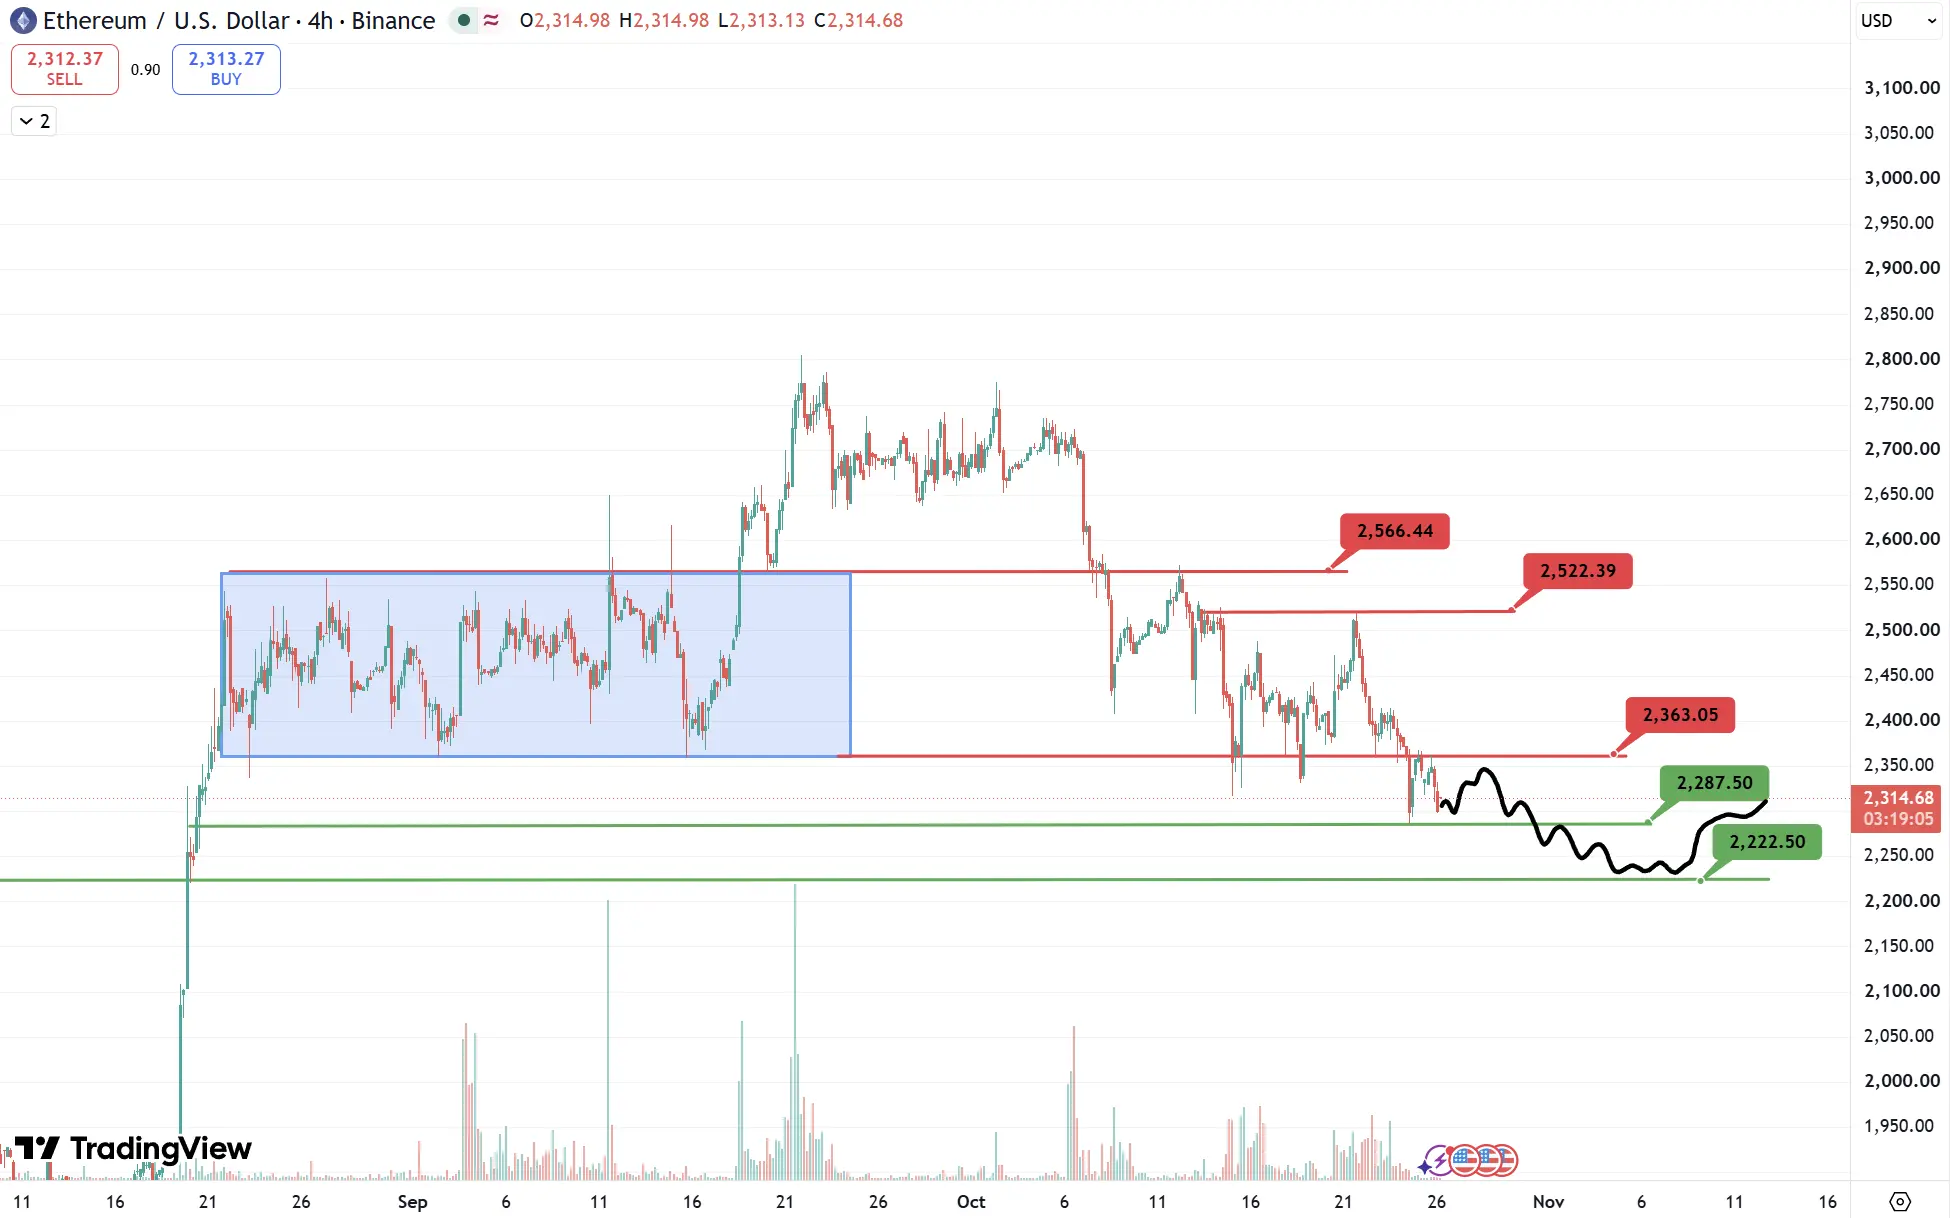
Cryptocurrency market changes this week (October 19, 2026 - October 25, 2026): BTC and ETH rose initially but then fell, with the mid-week rebound failing to continue. BTC rose from about $81,953 on October 19 to about $84,117 on the 21st, then fell back to $81,164 on the 23rd; during the same period, ETH rose from about $2,407 to $2,473, then fell back to $2,387. As of 09:00 on October 25, Beijing time, BTC was at $80,688.28 and ETH was at $2,354.14, not yet the closing price for the week. Weakness in tech stocks, rising oil prices, and interest rate uncertainty are suppressing risk appetite; from the 19th to the 23rd, BTC spot ETF saw a net inflow of about $309 million, while ETH spot ETF experienced a net outflow of about $221 million, indicating significant differentiation in institutional funds.
Cryptocurrency market forecast for next week (October 26, 2026 - November 1, 2026): High volatility is expected, with direction depending on the Federal Reserve's statements, PCE, and ETF fund changes. If concerns about tightening ease and institutional buying continues, BTC is expected to retest around $84,000 this week, while ETH needs to reclaim $2,400 first; if the policy is hawkish or tech stocks continue to decline, the psychological level of $80,000 for BTC may be tested again, and ETH also faces the risk of further weakness. These price levels are observation points, and are currently insufficient to confirm a trend reversal, especially with the need to be cautious of leveraged liquidations amplifying volatility before and after the meeting.
3. Industry and Sector Hotspots
This week's focus is on stablecoin payments, bank deposit tokens, and compliance infrastructure. On October 19, JPMorgan announced the expansion of JPM Coin deposit tokens to Ethereum for approved institutional clients; HSBC's Hong Kong dollar stablecoin RedCoin was launched on PayMe this week to facilitate personal transfers and merchant payments; on October 21, the U.S. OCC released the final rules for the implementation of the GENIUS Act, covering reserves, redemptions, custody, and risk management, set to take effect on January 18, 2027. The common direction is that on-chain funds are beginning to connect banks and actual payment scenarios more deeply, but the legal attributes of deposit tokens and stablecoins differ, and the growth in business adoption does not necessarily translate into increases in public chains or related tokens.
II. Market Hotspot Sectors and Potential Projects for the Week
1. Overview of Potential Projects
1.1. Detailed explanation of total financing of $12 million, led by Hack VC, with participation from Nomad Capital, Pi Network, and 10K Ventures ------ Building AI-driven intelligent robotic execution infrastructure Axis Robotics
Introduction
AXIS Robotics is a distributed training infrastructure for Physical AI, where anyone can participate and contribute computing and training data. Users do not need to purchase robotic hardware; they can control robots to complete simulation tasks and generate large-scale training data through a browser, collaboratively building the "brain" of the next generation of intelligent robots.
AXIS Robotics adopts a Simulation First technology approach: first, training data is collected through a browser-based robot simulation environment, then high-fidelity data augmentation techniques are used to massively expand the dataset, ultimately training intelligent control strategies (Policy) that can be directly deployed to real robots, achieving seamless migration from virtual simulation to real robots.
Protocol Element Analysis
AXIS Technology Architecture (The AXIS Stack)
- End-to-end robotic training pipeline
AXIS has built an end-to-end robotic training infrastructure that gradually transforms natural language tasks into deployable control strategies (Robot Policy) for real robots. The entire process covers five stages: task generation, behavior data collection, data augmentation, model training, and real robot deployment, achieving a complete closed loop for intelligent robotic training.
- System Overview
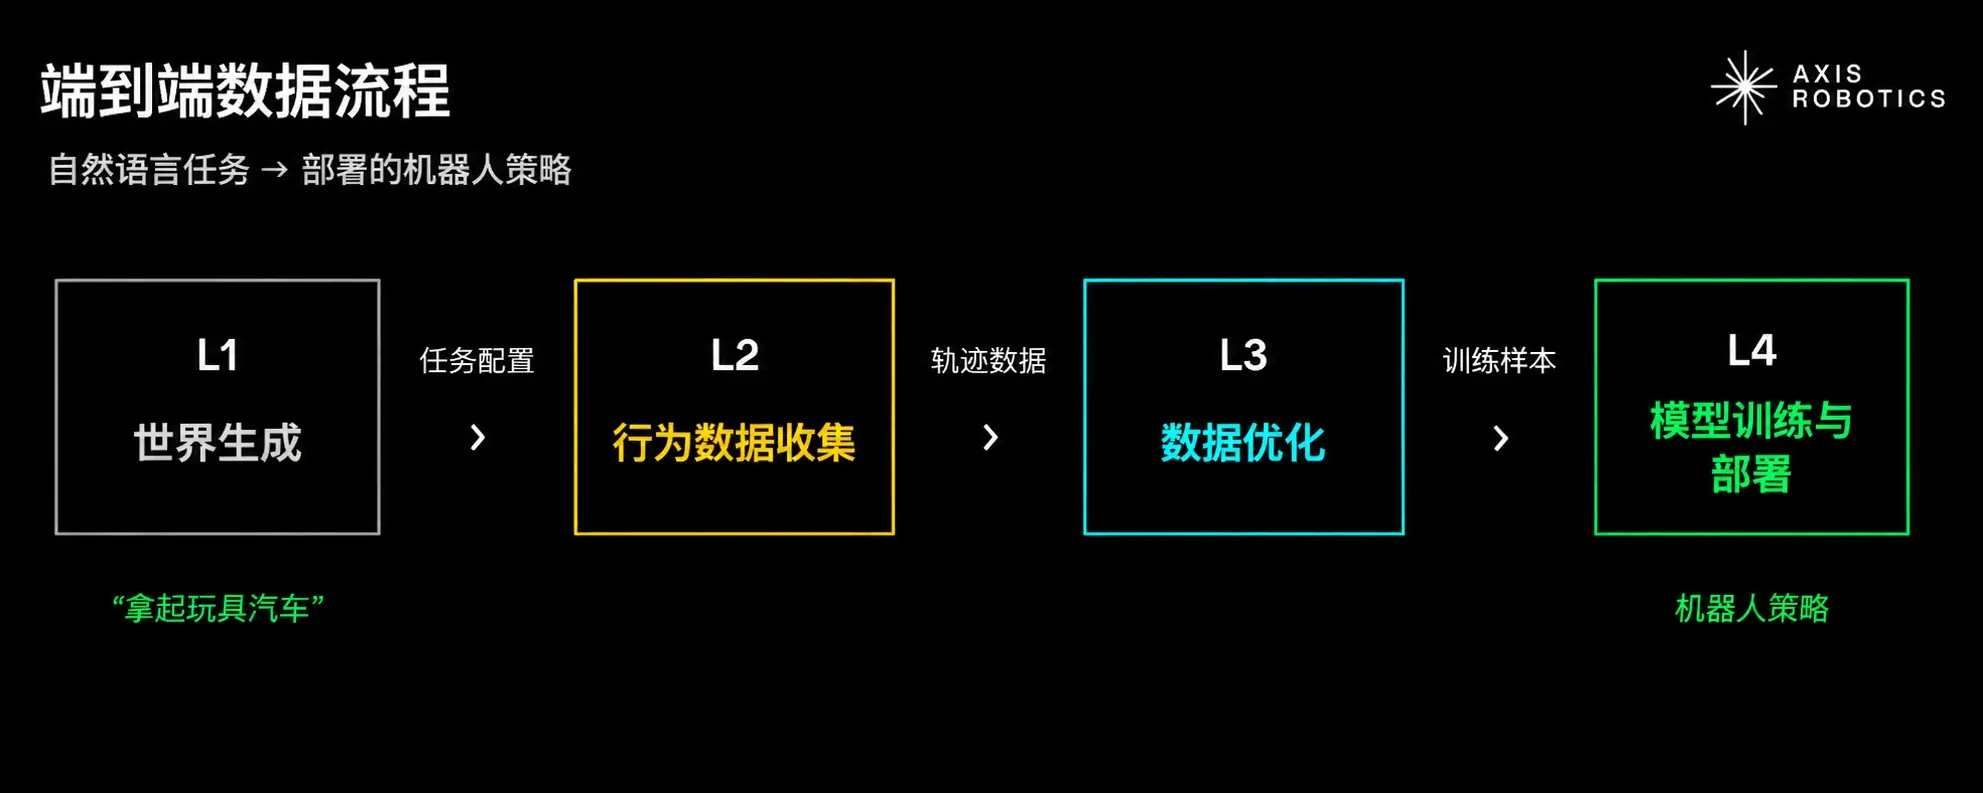
The entire AXIS architecture adopts a four-layer pipeline design, with each layer responsible for different stages of data processing and model building, ultimately generating intelligent control strategies that can be deployed to real robots.
- Detailed explanation of the four-layer architecture (The Four Layers in Action)
L1 ------ World Generation
The system first receives a natural language task description (e.g., "Pick up the toy car on the table"), which is automatically parsed by the Task Generation Engine and broken down into structured information such as task configuration, scene configuration, and target object configuration.
Subsequently, the Assets Manager automatically matches the corresponding objects from an asset library consisting of over 2,000 3D models, and can also automatically create new 3D models using Image-to-3D technology.
After preparing the objects, the 2.5D Layout Generator automatically generates the robot operating environment, while the Layout Supervisor continuously verifies and corrects the scene until it meets the task requirements. Meanwhile, each task automatically generates a corresponding Success Checker for subsequent automatic evaluation of whether the robot has completed the task.
L2 ------ Behavior Collection
The data collection phase allows participation via a browser.
Contributors do not need robotic hardware; they can remotely control the simulated robot to complete tasks using a keyboard, mobile phone, or game controller through the browser.
The robot's physical simulation runs locally compiled to WebAssembly using MuJoCo, so no GPU, software installation, or specialized equipment is required.
Each operation of about 1-2 minutes generates a complete robot trajectory, which includes:
Timestamp
Robot joint states
Object poses
Control commands
Task metadata
All trajectories use a unified data format compatible with different robotic simulation platforms. Data that has been reviewed will also record on-chain data provenance and generate a unique Data ID on the Base network to ensure data traceability.
L3 ------ Data Refinement
The collected raw trajectories first undergo data cleaning, including:
Static Frame Removal
Savitzky-Golay smoothing filter
Cubic Spline interpolation, increasing the sampling frequency from 6-8Hz to 20Hz
Removal of low-quality data
After cleaning, the system replays the trajectories in Isaac Sim on a GPU server and uses the Augmentation Engine to randomly adjust:
Lighting
Textures
Materials
Physical parameters
Camera angles
Ultimately, a single robot trajectory is expanded into thousands of high-fidelity training samples that have undergone domain randomization, significantly enhancing the model's generalization ability.
L4 ------ Model Training & Deployment
The enhanced dataset will be used to train two types of robotic control models:
Task-specific models: Using behavior cloning, diffusion policy, and other imitation learning methods to learn execution strategies for specific tasks.
General vision-language-action models (Vision-Language-Action, VLA): Training robotic models with stronger generalization capabilities by combining natural language objectives.
Models will first be thoroughly tested in randomized simulation environments to verify their stability and success rates under different initial conditions. After validation, they will be deployed to real robots (currently supporting Franka Research 3) for Sim-to-Real validation, achieving reliable migration of robotic strategies from virtual environments to the real world.
Brief Overview of Protocol Technical Architecture
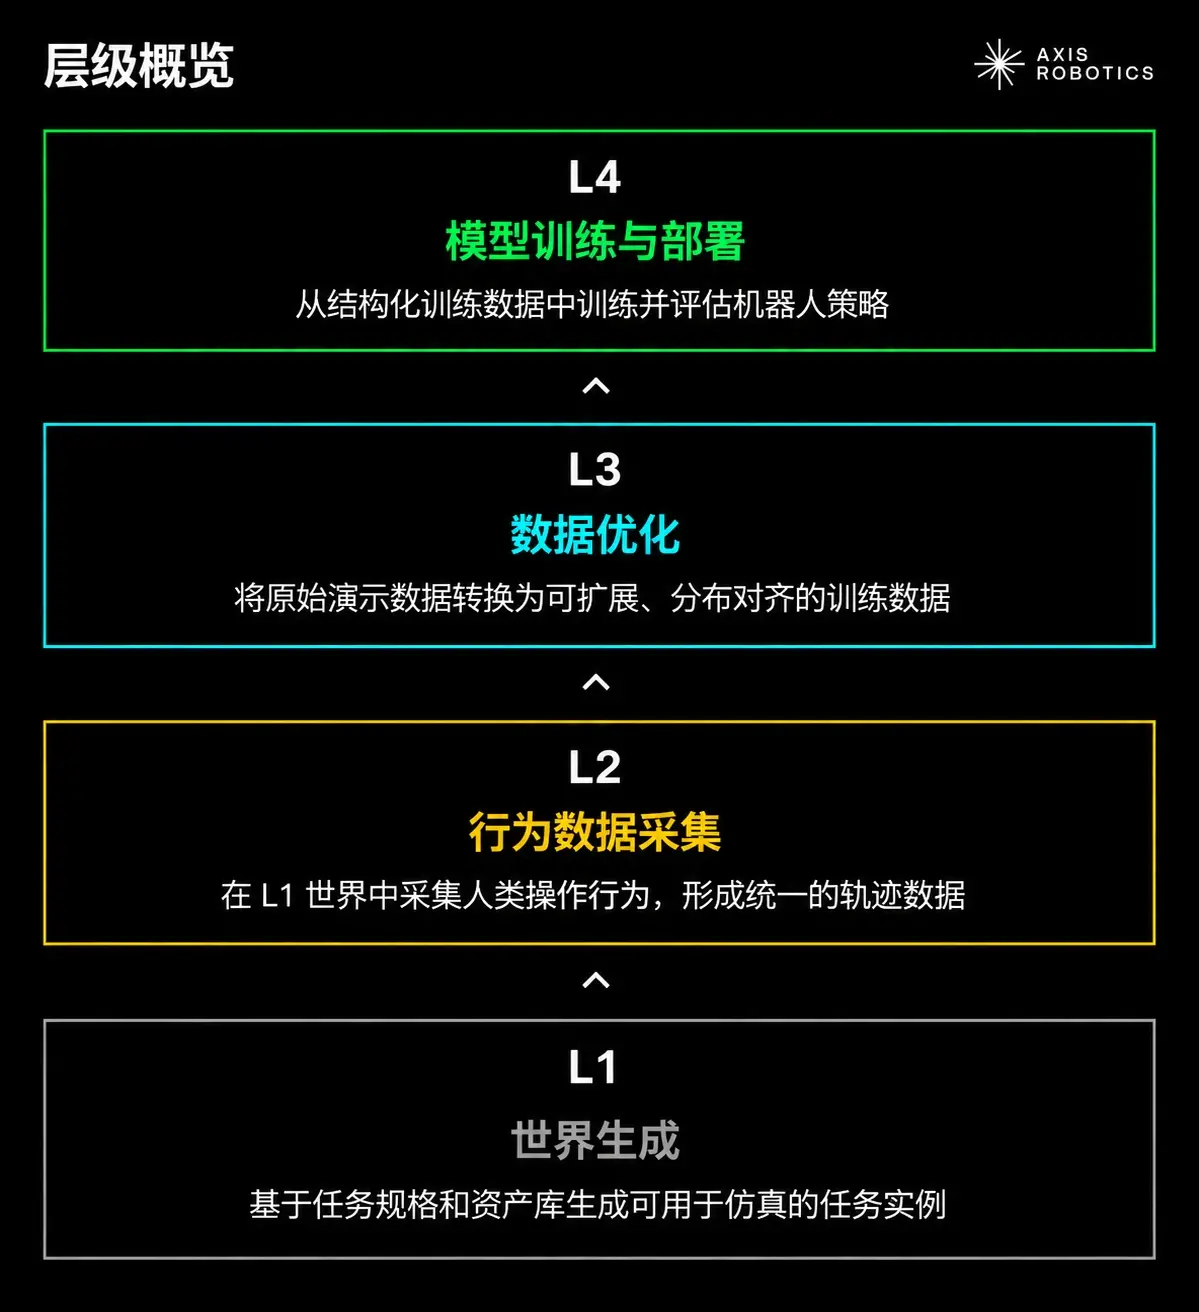
- L1 --- World Generation
L1 is responsible for generating the simulation environment and task instances required for robotic training. The system receives natural language task descriptions and, combined with over 2,000 asset library objects, automatically generates runnable simulation tasks that include scene structure, object layout, physical parameters, and task success detectors.
This layer is based on MetaSim (a scene description language independent of specific simulators), decoupling task semantics from the underlying simulator. The generated tasks can be directly converted into formats such as MJCF, USD, URDF, and are compatible with different simulation environments like MuJoCo and IsaacSim.
Consumes
Asset library (EmbodiedGen, Kujiale, image reconstruction data)
Natural language task descriptions
Scene layout constraints
Produces
Parameterized task instances
Cross-simulator compatible scene configurations
Abstraction
Separates task logic from specific simulator implementations, allowing subsequent layers to operate without handling different simulator interfaces.
Key components
MetaSim scene description language
LLM-driven task generation engine
Automated 2.5D scene layout generation
Unified USD / URDF / MJCF Asset Pipeline
- L2 --- Behavior Collection
L2 introduces human operational behavior into the simulation environment created by L1 and converts it into structured trajectory data executable by robots.
Users do not need to install software or use specialized equipment; they can control the simulated robot through a browser using a keyboard, mobile phone, game controller, or VR. The system runs physical simulations locally through MuJoCo WebAssembly and maps different input methods to unified robot control commands, enabling cross-device and cross-robot form data collection.
Each valid trajectory will record on-chain source information (Base Network Data ID), ensuring the training data has traceability.
Consumes
Interactive task instances generated by L1
Human control signals from multiple devices and modes
Produces
Robot trajectory data with source proof:
{Robot state, object state, control actions, task information, language targets, Data ID}
Abstraction
Decouples human operational intent from the specific structure of robots, allowing data from different devices and robot forms to be used uniformly.
Key components
MuJoCo WASM browser runtime environment
Cross-form robot control
Grasp template interpolation system
Decentralized data collection network
Base on-chain data source records
- L3 --- Data Refinement
L3 is responsible for transforming low-quality, sparse human demonstration data into large-scale, high-quality datasets suitable for model training.
This layer not only performs simple data cleaning but also constructs training data that can support real-world generalization through Distribution Engineering.
The process is divided into two parts:
Data Cleaning:
Remove static frames
Savitzky-Golay smoothing
Cubic spline interpolation
Increase sampling frequency from 6--8Hz to 20Hz
Data Augmentation:
Using the IsaacSim GPU simulation environment, trajectories are randomized in multiple dimensions, including:
Scene structure
Materials
Lighting
Camera parameters
Physical properties
Ultimately, a single trajectory is expanded into thousands of high-fidelity training samples.
Consumes
Original trajectory data with source proof from L2
World configuration data from L1
Produces
Distribution-aligned training data:
Cleaned trajectories × Domain randomization enhancement × Multi-view RGB / depth / segmentation data
Abstraction
Decouples data scale from manual collection costs, allowing the model to receive structured data distributions rather than individual demonstration samples.
Key components
Trajectory cleaning process
IsaacSim GPU replay
Domain Randomization data augmentation system
Multi-view camera generation
- L4 --- Model Training & Deployment
L4 utilizes the structured training data generated from L1 to L3 to train and output deployable robot control policies.
This layer supports various training methods, including:
Behavior Cloning (BC)
Diffusion Policy
Vision-Language-Action (VLA) model
Different models are trained based on a unified data interface, allowing the system to compare the performance of different algorithms in complex task environments.
AXIS focuses more on the real generalization ability of the model rather than just benchmark test scores. The model needs to undergo:
Cross-simulator validation
Multi-scene layout testing
Strong visual disturbance testing
Sim-to-Real real robot deployment validation
The final model will be deployed to real robots (currently supporting Franka Research 3). At the same time, each model retains a complete data source link, traceable to L3 data augmentation, L2 data collection, and L1 world generation processes, and associates the original contributors through on-chain Data ID.
Consumes
Distribution-aligned training data from L3
Evaluation environment configuration from L1
Produces
Task-specific robot policies
General robot models
Sim-to-Real validation results
Deployable model files
Abstraction
Decouples learning algorithms from data infrastructure, allowing different training methods to access a unified data system without focusing on data collection and enhancement processes.
Key components
Task-specific imitation learning (BC / DP)
General VLA model
Cross-simulator validation
Sim-to-Real testing
Multi-world × Multi-robot form generalization evaluation
RoboVerse: Unified Simulation Framework
RoboVerse provides a unified interface framework connecting various robot simulation backends, enabling different simulators to work together through standardized APIs.
Its core idea is that different simulators have their own advantages at different stages of the robot training process. For example, some simulators are better suited for high-precision physical calculations, while others are more suitable for large-scale data generation or visual simulation. Therefore, RoboVerse abstracts the underlying differences between different simulators and unifies them under a common interface, allowing each stage of the robot training process to automatically call the most suitable simulation environment.
This design avoids developers having to repeatedly develop adaptation code for different simulators, improving the efficiency of robot simulation, data generation, and model training processes, while providing a unified infrastructure for generalization training across multiple environments and robot forms.
Built on MetaSim
The cross-simulator capability of RoboVerse is built on MetaSim. MetaSim is a unified scene representation and description language, whose core function is to decouple task definitions from specific simulator implementations, allowing the same set of tasks, assets, and trajectory data to freely migrate between different simulation environments.
Through MetaSim, AXIS can treat different simulators as interchangeable execution backends without developing adaptation logic for each simulator separately.
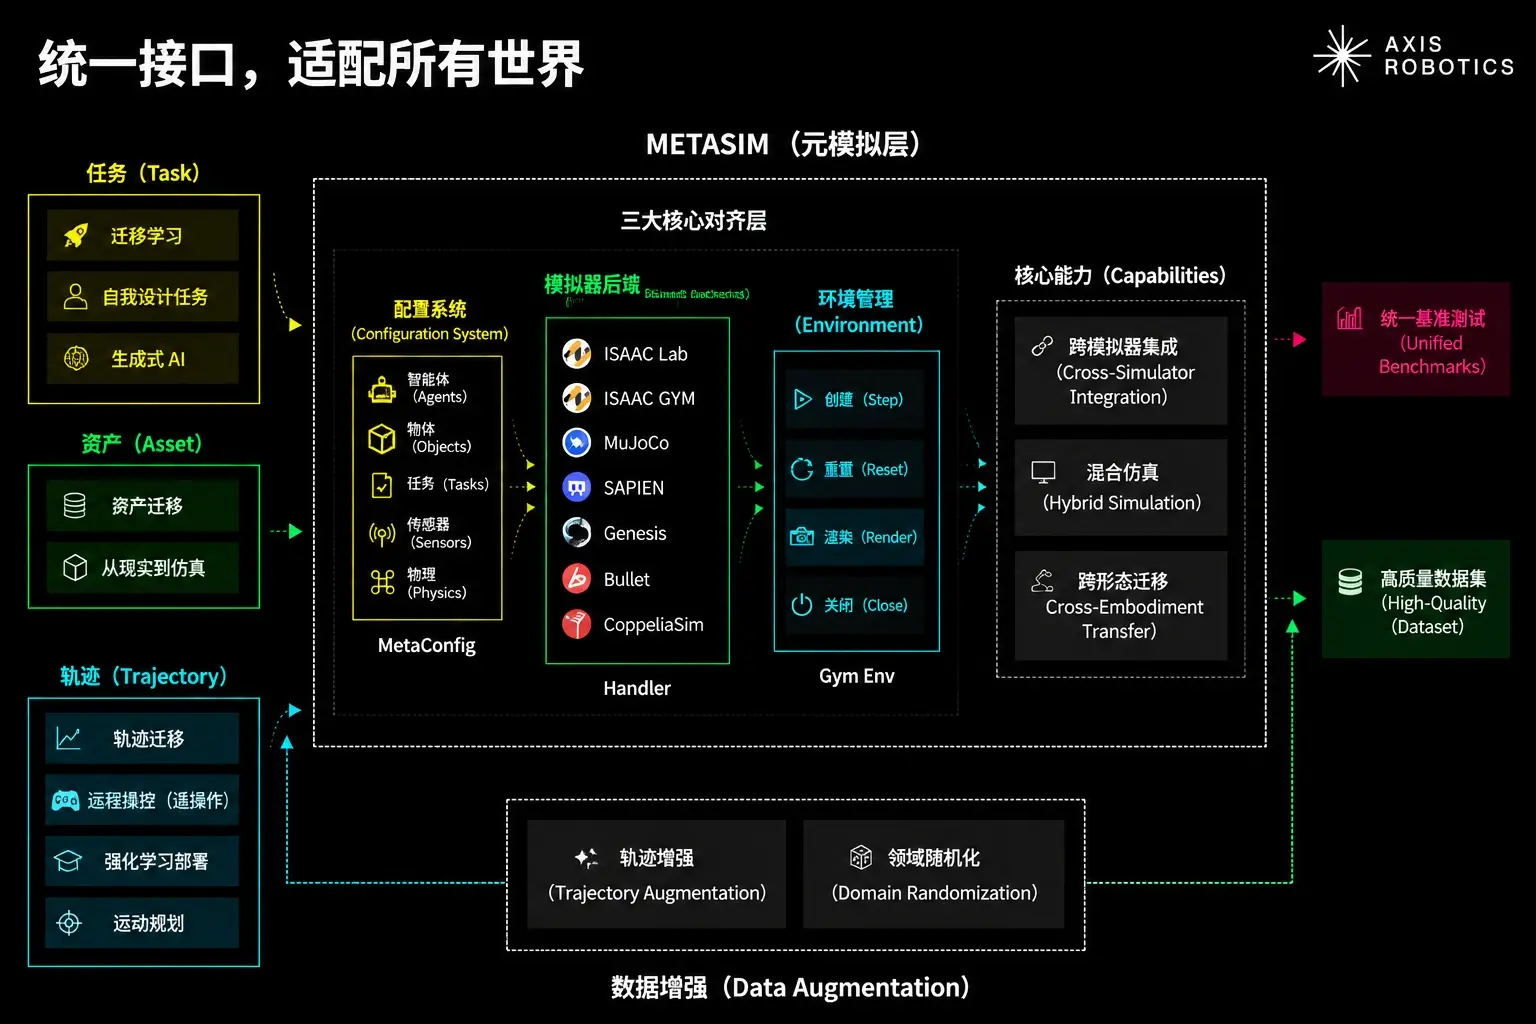
MetaSim Architecture: One Interface for All Worlds
MetaSim primarily provides the following capabilities:
Standardized Scene Graphs
MetaSim uses a unified format independent of specific simulators to describe scene information, including:
Objects
Articulations
Materials
Physics Properties
This allows different simulators to share the same set of scene definitions.
Automatic Translation
MetaSim can automatically compile the unified scene description into the native formats required by different simulators:
MuJoCo → MJCF
IsaacSim → USD
Other simulators → URDF and other formats
Thus, the same task environment can run on different simulation backends without needing to be rebuilt.
Asset Normalization
MetaSim uniformly processes assets in different simulators, including:
Coordinate system normalization
Collision model unification
Visual property synchronization
This ensures that robot, object, and environment assets remain consistent across simulators.
Programmatic Scene Generation
MetaSim provides composable programmatic APIs, allowing the system to automatically generate complex task scenes. This capability supports the Task Generation Engine to create diverse training environments on a large scale, providing richer data sources for robot models.
Core Value of MetaSim
Through this abstraction layer, AXIS can achieve:
Task definition migration across simulators
Robot assets reuse across environments
Trajectory data circulation across platforms
Standardization of training processes
Ultimately, different simulation backends are no longer independent systems but become composable modules within the AXIS robot training pipeline.
RoboVerse v2: From Platform to Generalization Engine
If the goal of RoboVerse v1 was to unify robot simulation and learning interfaces—supporting multiple simulators, multi-task environments, and reinforcement learning (RL) / imitation learning (IL) plugins, then RoboVerse v2 further upgrades this infrastructure to a closed-loop, diversity-driven robot learning engine.
The core shift of RoboVerse v2 is from "A System That Runs"
to "An Engine That Manufactures Diverse Experience."
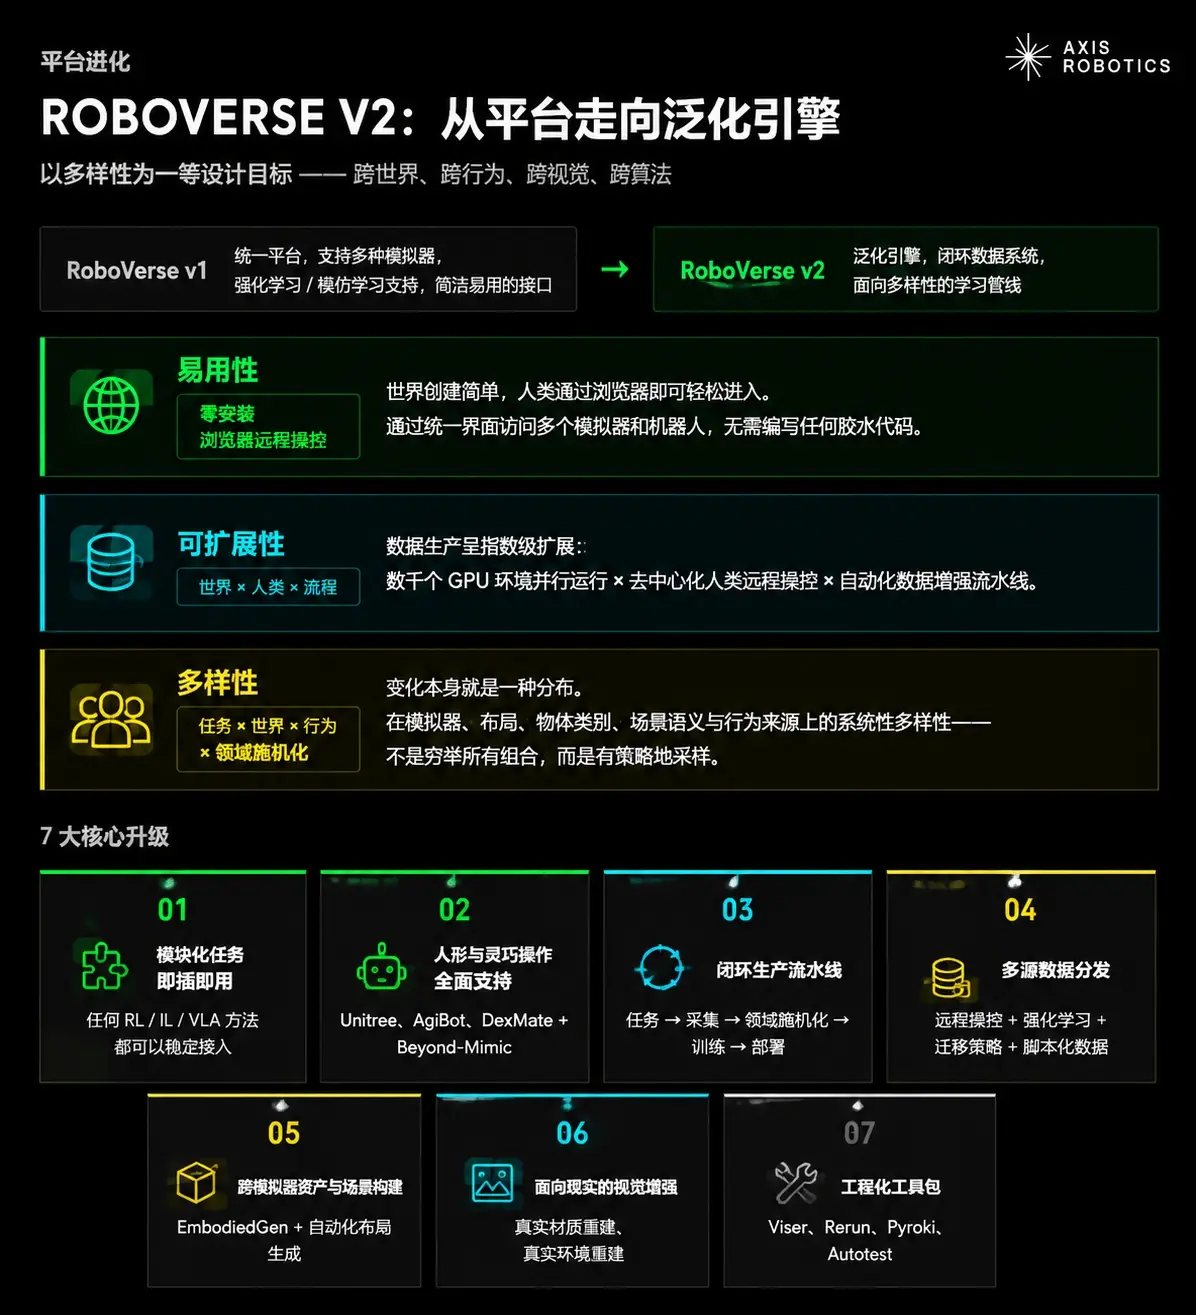
By combining world generation, behavior collection, data augmentation, and model training, RoboVerse v2 no longer just provides simulation environments but continuously produces data and experiences that support the enhancement of robot generalization capabilities. Its focus shifts from merely unifying simulators to building a scalable learning pipeline aimed at real-world robots.
Data Pipeline
Before data collection, training environments are created through automated task generation; after data collection, training data is optimized through trajectory cleaning and data augmentation.
This section introduces two automated engines around the artificial data collection process at both ends:
Task Generation Engine: Responsible for task creation before data collection;
Data Augmentation Engine: Responsible for trajectory processing and expansion after data collection.
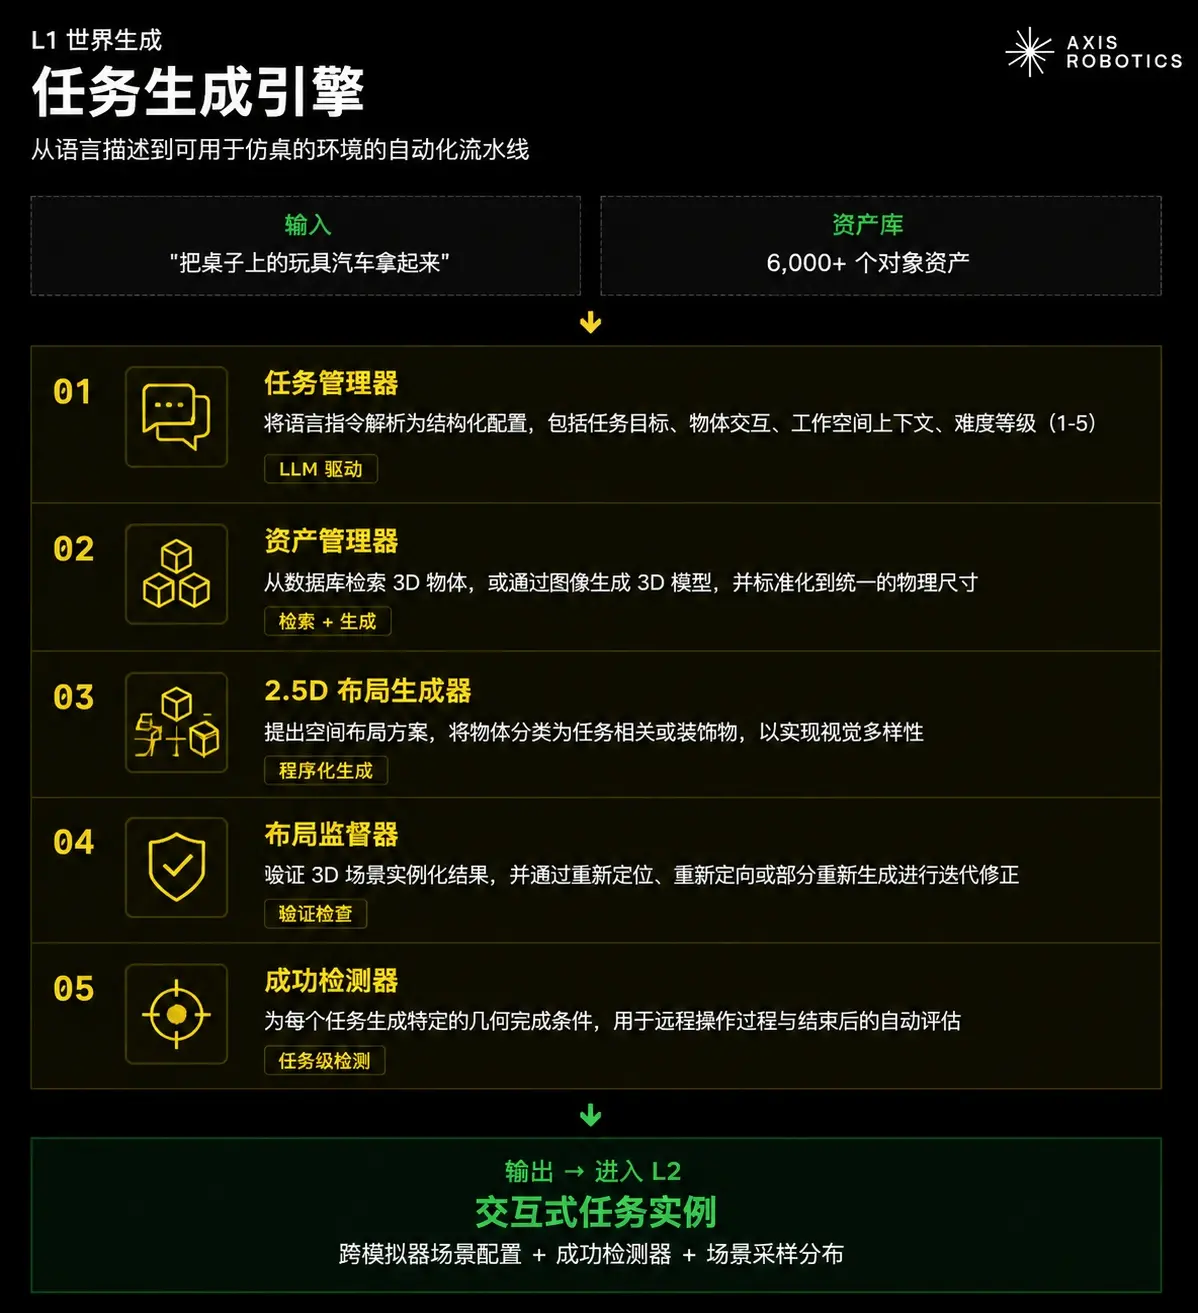
Pipeline 1: Task Generation
Task Generation Engine
An automated process consisting of 5 stages from language description to environments usable for simulators.
Before any user operates the controller, the system automatically constructs through the task generation engine:
Task Specifications
Simulator-ready Environments
Providing standardized training scenarios for subsequent robot behavior data collection.
Scenario Sampling
Once a valid task layout is constructed, the platform defines the initial condition distribution to generate diverse task instances. These distributions include object poses, scene clutter configurations, and variations in camera angles, achieving large-scale scene sampling while maintaining the core task semantics.
This is also key to the system's ability to achieve over 90 task categories, including tasks such as grasping and placing, pushing, classifying, dumping, opening/closing, stacking, and multi-step operation sequences.
Pipeline 2: Trajectory Cleaning
Trajectory Cleaning Before/After Comparison with Measured Results
Data collected from teleoperation may contain various anomalies, such as jitter caused by keyboard input, stalls, unintended oscillations, and invalid motion trajectories.
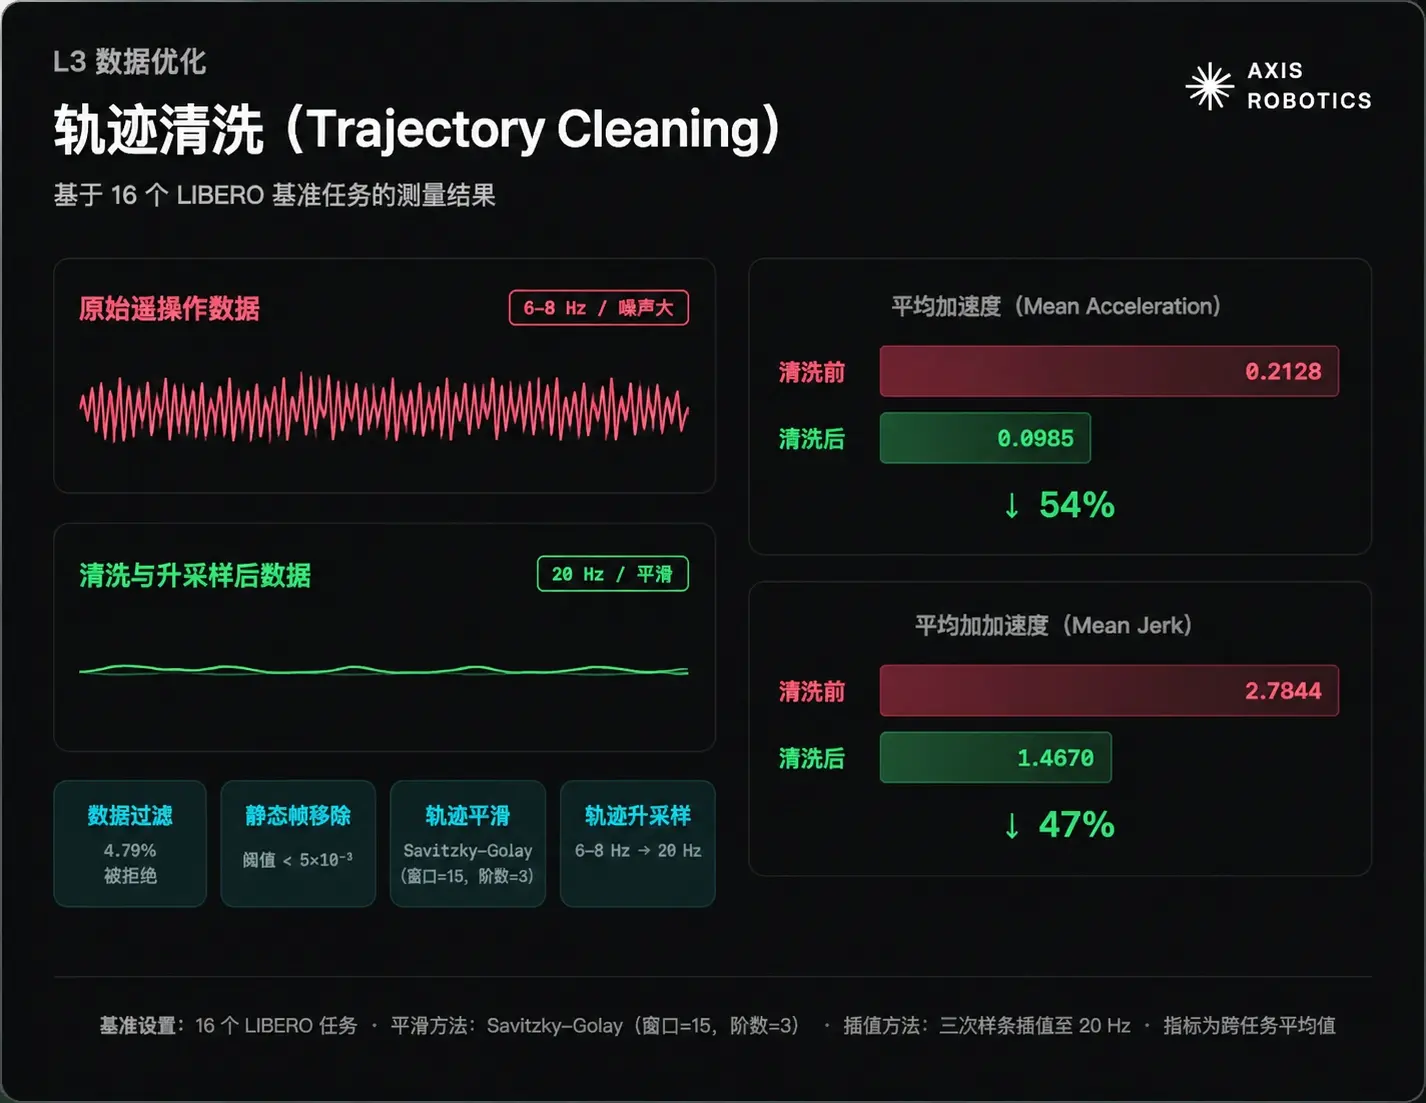
AXIS has designed a trajectory cleaning process that primarily achieves two goals:
Filter unusable episodes
Refine borderline trajectories
Filtering
When trajectories exhibit the following conditions, the system will directly reject them:
Data corruption or incompleteness;
Extreme State Discontinuities;
State transitions that do not comply with physical laws;
Failure to meet task-specific success constraints.
The system calculates the state change between adjacent frames and determines whether the change exceeds reasonable physical thresholds.
In multiple task test sets, the average rejection rate of this filtering process is approximately 4.79%.
Static Frame Removal
When the absolute change of all robot joints is below the set threshold (5×10⁻³), the frame is identified as a static frame and deleted.
This mechanism is used to remove invalid pauses caused by operator hesitation, stalls, etc., making the trajectory more continuous and effective.
Smoothing
AXIS uses a Savitzky-Golay filter to smooth the robot's motion trajectory:
Window Size: 15
Polynomial Order: 3
This method can reduce high-frequency noise generated during teleoperation, such as:
Sudden corrective actions;
Jitter caused by operational hesitation;
While maintaining the overall shape of the motion trajectory.
Among them, Gripper Joints will not participate in the smoothing process to maintain clear opening and closing changes during the robot's grasping and releasing actions.
Upsampling
The original teleoperation system's sampling frequency is only 6--8Hz, which cannot meet the subsequent high-frequency robot control and policy training needs.
Therefore, AXIS uses cubic spline interpolation to increase the trajectory sampling frequency to the target frequency of 20Hz.
Non-robot data (such as object states) will not undergo smoothing but will be interpolated separately to maintain time synchronization with the robot control steps.
Measured Results
In 16 benchmark tasks (LIBERO Suite) tests, the trajectory cleaning process significantly improved trajectory quality:
|--------------------------|--------|--------|--------| | Metric | Before Cleaning | After Cleaning | Improvement Effect | | Mean Acceleration | 0.2128 | 0.0985 | Reduced by 54% | | Mean Jerk | 2.7844 | 1.4670 | Reduced by 47% |
The cleaned trajectories are smoother and more suitable for robot policy training and cross-simulator trajectory replay.
Training
The training phase of AXIS is responsible for transforming the generated, cleaned, and augmented data into deployable robot policies and verifying the model's generalization ability in real environments through Sim-to-Real.
Types of Training Models
AXIS primarily trains two types of robot models:
Task-specific Policies
Based on Behavior Cloning (BC) and Diffusion Policy (DP), training robot policies for specific tasks, including:
Grasping and placing;
Drawer switches;
Dumping;
Button operations.
These models are optimized for specific operational skills, enhancing the robot's execution capability in fine operations and complex interaction tasks.
General-purpose VLA Models
Visual-Language-Action (VLA) models combine natural language instructions and visual information to enable robots to understand and execute unknown tasks, aiming for zero-shot generalization across tasks.
Training Protocol
AXIS conducts comparative training using three types of data:
Original teleoperation data: Unprocessed human operation data;
Cleaned data: Trajectory data after filtering, smoothing, and upsampling;
Cleaned + Augmented data: Large-scale training data generated through IsaacSim simulation and domain randomization.
By unifying tasks and training conditions, the effectiveness of data processing and augmentation on model performance is evaluated.
Evaluation
The model is first tested in a simulation environment:
Different object positions and scene layouts;
Different visual and physical conditions;
Unseen task environments.
It is then deployed to the Franka Research 3 (FR3) robot for real-world validation, testing:
Grasping;
Drawer operations;
Dumping;
Button operations.
The main evaluations focus on success rates, trajectory quality, and environmental generalization ability.
Key Results
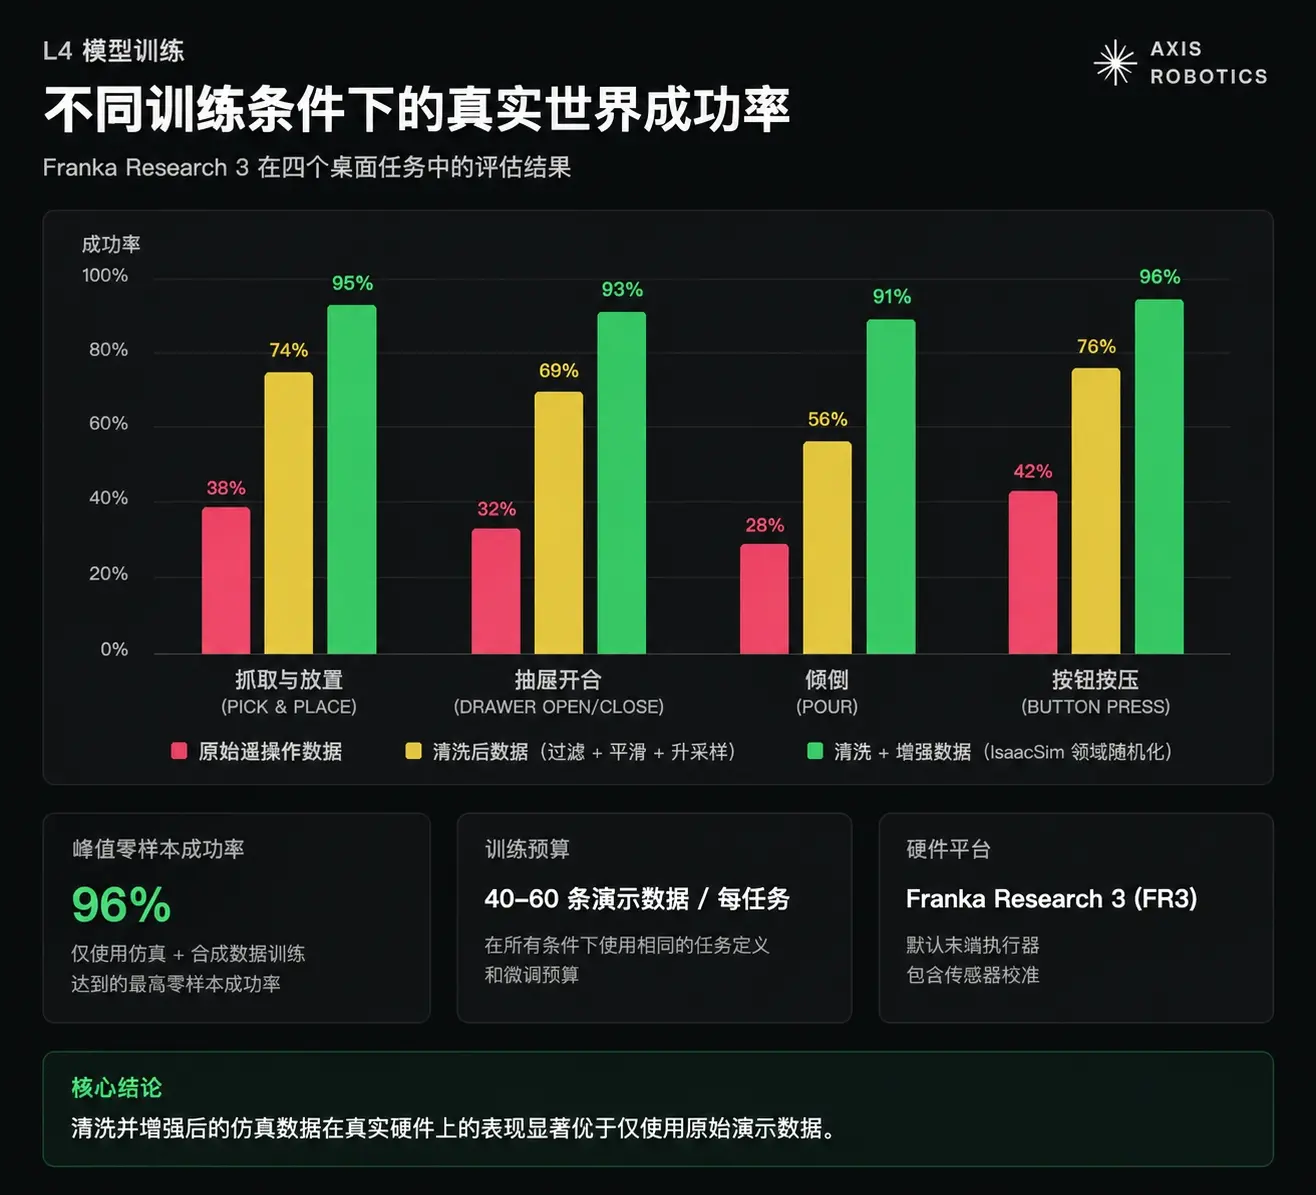
AXIS demonstrates that reasonably collected, cleaned, and augmented simulation data can train robot policies that adapt to real environments.
Its advantage lies in combining low-threshold browser data collection with high-performance GPU simulation training, achieving large-scale production of robot training data and accelerating the development of Physical AI models.
Related Research Foundations:
GraspVLA: Validates that pure simulation data can achieve over 90% Sim-to-Real transfer effectiveness for grasping;
SkillBlender: Supports combining multiple robot skills into complex multi-step behaviors.
Tron Comments
The advantage of Axis Robotics lies in its construction of an end-to-end robot training infrastructure aimed at Physical AI, integrating task generation, behavior data collection, data cleaning and augmentation, and model training deployment into a complete closed loop through a Simulation First approach. Its core competitiveness is utilizing technologies like RoboVerse and MetaSim to achieve a unified interface across simulators, collecting human operation data through low-threshold browser methods, and combining IsaacSim data augmentation and VLA/robot policy model training to generate generalizable robot intelligence data on a large scale, which is more efficient and scalable compared to traditional methods relying on real hardware data collection.
Its disadvantage is that robot AI is still in a rapid development stage, facing challenges in real-world deployment such as hardware differences, complex environmental generalization, and data scale requirements; at the same time, the platform's value highly depends on the contributions of ecological participants in data, the compatibility range of simulators, and the actual application of the robotics industry, with commercialization scale and long-term competitive barriers needing further validation.
II. Industry Data Analysis
1. Overall Market Performance
1.1. Spot BTC vs ETH Price Trends
BTC
ETH
III. Macroeconomic Data Review and Key Data Release Nodes for Next Week
This week's review (October 19, 2026 - October 25, 2026): On October 19, China announced a year-on-year GDP growth of 4.5% for the third quarter, rebounding from 4.3% in the second quarter, with a cumulative growth of 4.6% for the first three quarters; in September, the industrial value added above designated size increased by 5.5% year-on-year, but the cumulative growth of retail sales in the first three quarters was only 1.1%, reflecting stronger production than consumption. The initial jobless claims in the U.S. announced on October 22 were 194,000, a decrease of 6,000 from the revised previous value of 200,000, indicating that layoffs remain low. Overall, China's economic recovery is still uneven, while U.S. employment remains resilient.
Key Events Next Week (October 26 - November 1): On October 29 at 02:00, the Federal Reserve will announce its interest rate decision, followed by a press conference at 02:30; on the same day at 20:30, the preliminary value of the U.S. third-quarter GDP, September PCE and core PCE, personal income and expenditure data will be released, along with initial jobless claims; on October 30 at 20:30, the U.S. third-quarter Employment Cost Index will be announced. Focus on the combination of "Federal Reserve policy guidance + core PCE + GDP" to assess interest rate direction, inflation stickiness, and growth resilience.
IV. Regulatory Policies
United States: Stablecoin Implementation Rules Finalized, Crypto Tax Reform Bill Proposed
On October 21, the Office of the Comptroller of the Currency (OCC) announced the final rules for the implementation of the GENIUS Act, clarifying the reserve assets, redemption, capital, risk management, custody, and audit report requirements for payment stablecoin issuers under its jurisdiction, also covering eligible foreign issuers. The rules are set to take effect on January 18, 2027; anti-money laundering and sanctions-related regulations will be formulated separately. This week marks the "final rule publication," and it has not yet entered the effective stage, nor does it mean that all issuance applications are open for acceptance.
On October 22, a senator proposed the ADAPT Act, which aims to simplify the profit and loss tracking requirements when using U.S. dollar stablecoins regulated by the GENIUS Act to purchase goods and services, exempting network fees not exceeding $10, while extending anti-tax avoidance rules such as wash sales and presumed sales to digital assets. Its significance lies in promoting both payment facilitation and tax rule unification, but it is currently only a legislative proposal and has not changed existing tax obligations.
United Kingdom: Consultation Launched on DeFi Compliance and Crypto Business Regulatory Boundaries
On October 21, the Financial Conduct Authority (FCA) published a consultation draft GC26/7 on DeFi guidelines, explaining how regulated entities should comply with existing operational resilience, financial crime prevention, and anti-money laundering requirements when using DeFi to provide financial services. The consultation period ends on November 18, with final guidelines planned for release in January 2027. This is a consultation on the applicability of existing obligations, not a comprehensive new DeFi law introduced this week.
On the same day, the FCA released CP26/36, seeking opinions on the regulatory boundaries of crypto assets and certain exclusions, helping businesses determine which activities require authorization and which may qualify for exclusion. The two consultations jointly advance the preparation for the implementation of the UK's crypto regulatory framework but should not be interpreted as a comprehensive exemption for related businesses.
France: Four Major Financial Regulatory Authorities Jointly Propose MiCA Revision Suggestions
From October 20 to 21, the French Treasury, the Financial Markets Authority (AMF), the Bank of France, and the Prudential Supervision and Resolution Authority (ACPR) announced joint recommendations for the EU MiCA review. Key points include cross-border issuance and reserves of stablecoins, redemption guarantees, strengthening regulation of major crypto service providers, and clarifying the responsibilities of DeFi intermediaries, as well as regulatory arrangements for staking and crypto lending.
These recommendations reflect France's push for further improvement of European crypto regulation, but they are position papers submitted for EU policy review and have not yet become results of EU legislative amendments, nor do they immediately introduce new compliance deadlines for businesses.
 Risk warning Risk warning